Loading...
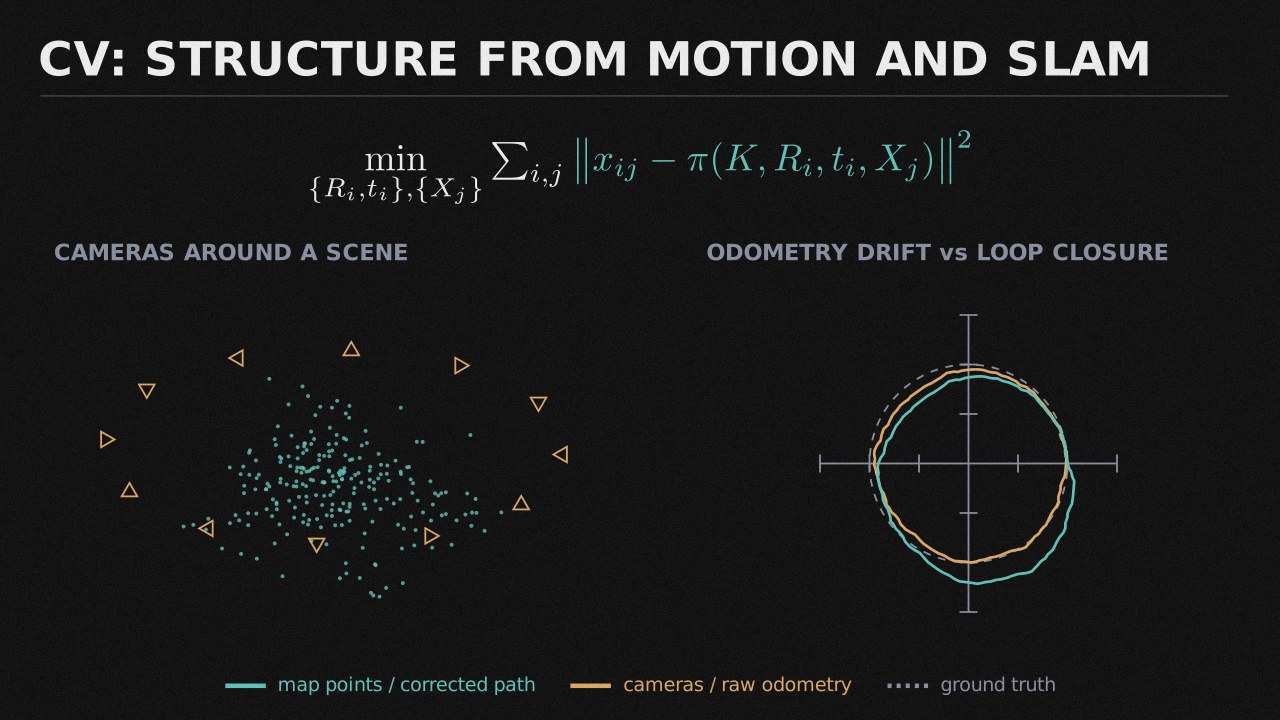
CV: Structure from Motion and SLAM — all 16 problems
Camera calibration, pose estimation, structure from motion, and simultaneous localization and mapping.
Camera calibration, pose estimation, structure from motion, and simultaneous localization and mapping.