3D Vision Projects
Multi-view geometry and point clouds: triangulate a scene from two cameras and register point clouds with ICP.
2 projects · GPU notebook · Premium only
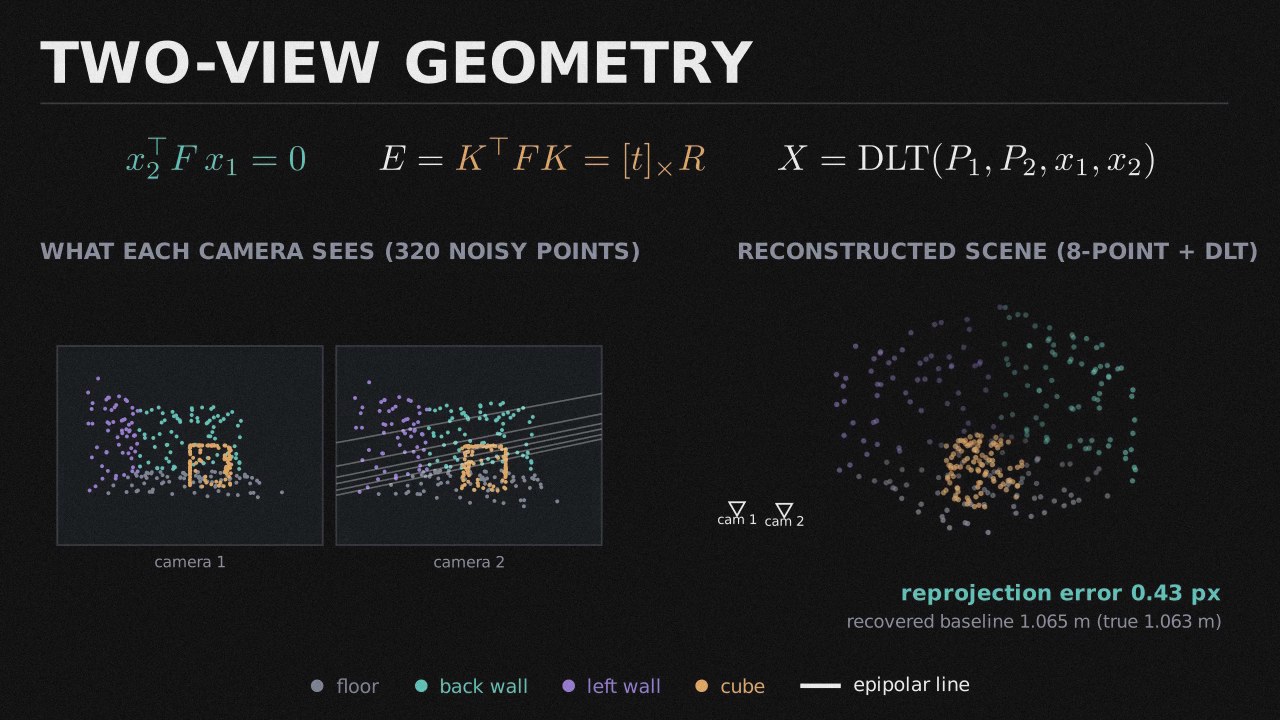
Two-View Geometry: Triangulate a Scene
PROReconstruct a 3D scene from two photos, using only NumPy. You'll build a synthetic room with a cube in it, project it into two calibrated cameras with pixel noise, and estimate the fundamental matrix with Hartley's normalized 8-point algorithm. Then you'll draw epipolar lines, recover the relative pose from the essential matrix using the cheirality test, and triangulate every point with linear DLT. You'll finish by measuring reprojection error and overlaying the reconstruction on ground truth. Nothing to download.
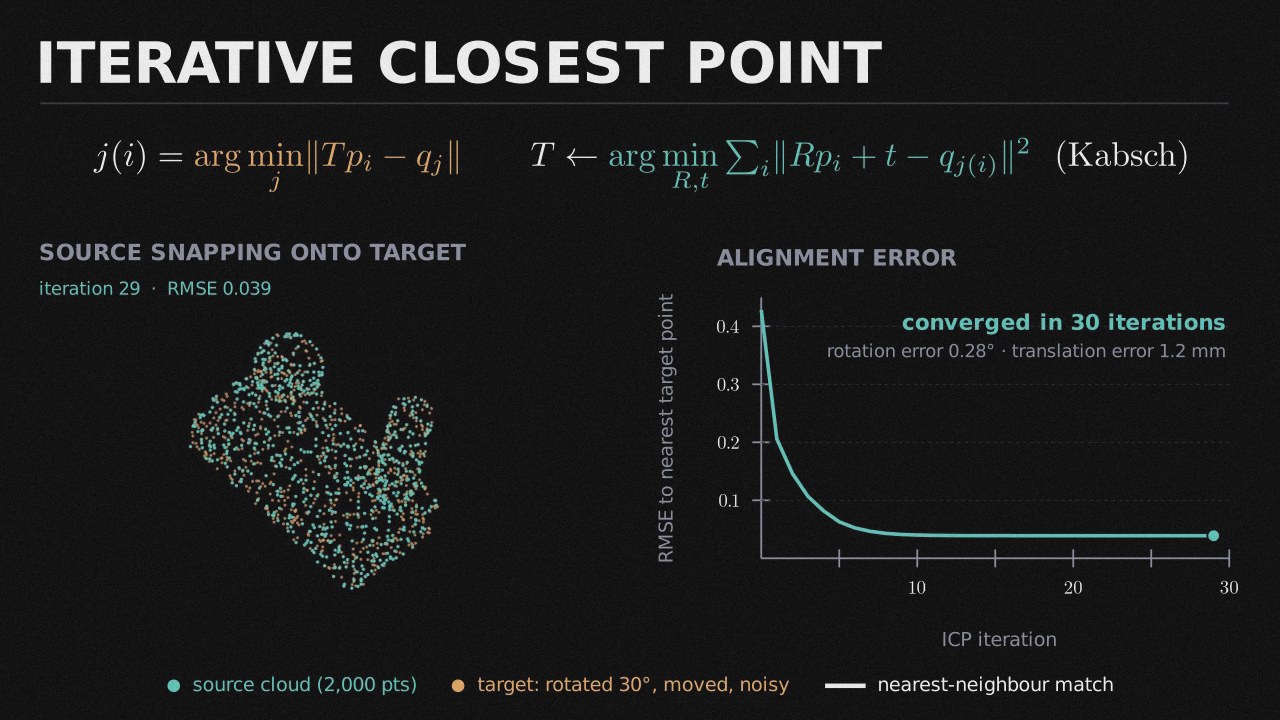
Point Cloud Registration with ICP
PROAlign two 3D scans of the same object with Iterative Closest Point, written from scratch. You'll sample point clouds from an asymmetric trimesh model and hide a known rigid transform plus sensor noise in the target. Then you'll implement the Kabsch/SVD best-fit transform and build point-to-point ICP on a KD-tree, tracking convergence. You'll stress-test ICP with large initial rotations and cluttered scans, add a trimmed variant that rejects outliers, and check your result against trimesh's built-in ICP. Nothing to download.